The Humanoid Delusion: Why 100-Meter Sprints Won't Wash Your Dishes
As viral humanoid robot games showcase superhuman sprints and flips, the engineering reality of domestic labor reveals why stadium athletic feats cannot conquer the tactile chaos of household chores.
The Humanoid Delusion: Why 100-Meter Sprints Won't Wash Your Dishes
In late August 2026, social media feeds across the globe were inundated with viral video clips from the 2nd World Humanoid Robot Games in Beijing. Audiences watched in awe as gleaming bipedal machines sprinted one hundred meters in 9.39 seconds—eclipsing the biological world record—before executing flawless gymnastics flips and high jumps over stadium hurdles. Financial analysts heralded the arrival of the "Physical AI Era," while robotics startups enjoyed multi-billion-dollar public market debuts.
Yet, stepping away from the choreographed stadium lights and entering an ordinary suburban home, a profoundly different reality emerges.
The very same machine that can sprint at thirty-five kilometers per hour on a flat rubberized track remains completely incapable of clearing a dinner table, folding a warm fitted bedsheet, or retrieving a fragile porcelain teacup from a crowded dishwasher without crushing it. In my previous essay, Your Robot Housemate, I documented the subtle, quiet arrival of domestic intelligence into our private living spaces. Today, we must confront the central illusion driving the robotics industry: The Humanoid Delusion.
We have spent tens of billions of dollars engineering Olympic athletes out of titanium and carbon fiber, while ignoring the humble, complex reality of domestic physical labor.
Moravec's Paradox at the Kitchen Sink
To understand why humanoid robotics has stalled at the threshold of the home, one must revisit a fundamental principle first articulated by Hans Moravec in the 1980s: what is hard for humans is easy for computers, and what is easy for humans is brutally difficult for computers.
Sprinting, jumping, and backflips are essentially dynamic physics calculations. They can be modeled using inverted pendulum equations, closed-loop torque feedback, and high-frequency inertial measurement units (IMUs). Once the mathematical constraints of balance, friction, and momentum are solved, a robot can execute dynamic athletics with superhuman precision.
Domestic chores, by contrast, are an endless gauntlet of unstructured chaos:
+-------------------------------------------------------------------------+
|                  THE DOMESTIC PHYSICAL AI BOTTLENECK                    |
|                                                                         |
|  Dynamic Locomotion (Stadium Arena):                                    |
|  [ Rigid Surface ] + [ Known Physics Equations ] ===> Superhuman Speed  |
|                                                                         |
|  Domestic Manipulation (Living Room):                                   |
|  [ Deformable Textiles ] + [ Variable Textures ]                        |
|  [ Cluttered Lighting ] + [ Fragile Ceramics ]                          |
|  |=================== The Sensory Tactile Barrier ====================| |
+-------------------------------------------------------------------------+
When a human washes a glass or folds a cotton towel, we do not perform rigid mathematical geometry. We rely on billions of mechanoreceptors embedded in our fingertips to detect micro-slips, surface moisture, fabric tension, and structural compliance in real time. We effortlessly manipulate deformable objects—items that change shape continuously as they are touched.
In laboratory benchmarks, tactile sensing arrays like GelSight or high-density magnetic skin can approximate local shear forces, but integrating those high-frequency tactile streams into deep reinforcement learning manipulation policies in real time requires colossal compute budgets. A human infant can figure out how to grasp a wet strawberry without puncturing its skin in three attempts; a frontier vision-language-action (VLA) model running on an embedded GPU frequently requires hundreds of thousands of simulated demonstrations and still fails when ambient lighting shifts or the fruit is slightly overripe.
For a robotic actuator, handling a limp cloth or peeling a ripe peach represents a combinatorial nightmare. An end-effector with rigid tactile sensors either squeezes too hard (crushing the object) or grips too loosely (dropping it on the floor). Until physical AI achieves sub-millimeter tactile closed-loop feedback at millisecond latencies, the fastest sprinting biped remains functionally useless at the kitchen counter.
An engineering discipline that can build a machine to clear a two-meter hurdle has yet to master the quiet art of scrambling an egg.
The Anthropomorphic Trap: Vanity Over Utility
Why did the robotics industry insist on building bipedal humanoids in the first place?
The standard industry justification is that because our physical world was constructed by humans for humans—stairs, door handles, narrow hallways, kitchen countertops—robots must possess human geometry to navigate our environments.
In practice, this argument is an aesthetic vanity rather than an engineering necessity.
+-----------------------------------+
|   FORM-FACTOR TRADEOFF ANALYSIS   |
+-----------------------------------+
|                                   |
|   [ Bipedal Humanoid Model ]      |
|   • 60% Power Lost to Balance     |
|   • High Fall Risk & Liability    |
|   • 90-Minute Battery Endurance   |
|                vs.                |
|   [ Integrated Spatial Cobot ]    |
|   • Zero Balancing Overhead       |
|   • Silent Articulating Counter Arm|
|   • 14-Hour Continuous Operation  |
|                                   |
+-----------------------------------+
Walking on two legs is an extraordinarily inefficient method of terrestrial locomotion. A human body burns a massive portion of its caloric baseline simply maintaining bipedal equilibrium against gravity. In a battery-powered robot, maintaining active balance requires high-torque servomotors to micro-correct hundreds of times per second.
As a consequence, a typical eighty-kilogram humanoid consumes between eight hundred and fifteen hundred watts just standing still. Its battery is exhausted within ninety minutes of basic household mobility.
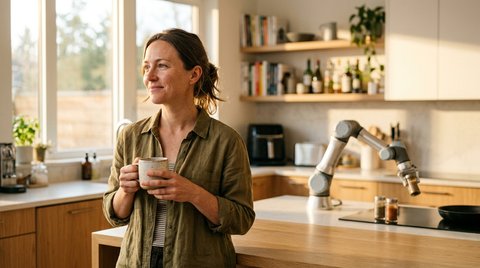
Compare this to specialized domestic form factors: a wheeled mobile base with an articulating robotic arm, or modular cobot arms integrated directly into kitchen cabinetry and laundry alcoves. By eliminating the mechanical burden of bipedal balance, power consumption drops by eighty-five percent, manufacturing costs plummet from $50,000 to under $3,000, and operational endurance extends to an entire twelve-hour household shift.
The home does not need a synthetic butler walking through the hallway; it needs intelligent, silent surfaces that assist human living.
The Economics of Domestic Reality
The financial dislocation in the consumer robotics sector is becoming impossible to disguise.
Throughout 2025 and 2026, robotics startups marketed the promise of the $15,000 "general-purpose household humanoid." Yet the true bill of materials (BOM) for a reliable bipedal machine—incorporating sixty high-density harmonic actuators, post-quantum vision processors, multi-spectral LiDAR, and synthetic skin arrays—routinely exceeds forty-five thousand dollars at manufacturing scale.
+-------------------------------------------------------------------------+
|                  HOUSEHOLD DOMESTIC ROBOTICS SPECTRUM                   |
|                                                                         |
|   Showcase Humanoids ($45k–$90k)       Integrated Home Cobots ($2k–$5k) |
|  [=============================]      [==============================]  |
|   • High maintenance fragility         • Zero fall risk / safe around kids|
|   • Stadium viral demos                • 99.8% chore completion reliability|
|   • Extreme battery drain              • Direct appliance integration   |
+-------------------------------------------------------------------------+
For the average household, an expensive, fragile machine that requires continuous maintenance contracts and poses a physical crushing hazard to children and pets is completely unviable. What consumers actually purchase are unobtrusive, task-specific automation ecosystems: robotic floor vacuum-mop scrubbers that dock invisibly into baseboards, automated induction cooktops with precision stirrers, and articulating laundry sorters.
The consumer market is voting with its capital: utility always triumphs over spectacle.
The 'Human-Reserved' Boundary and Domestic Sanctuary
Beyond the mechanical and economic barriers lies a profound psychological frontier: the sanctity of the domestic environment.
In the summer of 2026, widespread cultural debates erupted across Europe and Asia regarding the boundaries of domestic automation. When technology companies attempted to market humanoid companions for eldercare and early childhood supervision, civil society pushed back with remarkable unity.
The home is not a warehouse. It is the sanctuary of human vulnerability, intimacy, and rest.
+-----------------------------------+
|    THE DOMESTIC SANCTUARY SPLIT   |
+-----------------------------------+
|                                   |
|   [ Automated Utility ]           |
|   Dishwashing, Floor Cleaning,    |
|   Laundry Sorting, Food Prep      |
|                |                  |
|   [ Human-Reserved Realm ]        |
|   Caregiving, Emotional Presence, |
|   Child Nurturing, Intimacy       |
|                                   |
+-----------------------------------+
Humans welcome mechanical assistance with mundane, repetitive drudgery: we celebrate washing machines, dishwashers, and robotic vacuum cleaners. But we instinctively reject the presence of uncanny, synthetic humanoids attempting to simulate emotional empathy or replace human presence in caregiving roles.
True human-AI synergy does not mean outsourcing our humanity to machines; it means using machines to eliminate meaningless friction so we have more time to be fully human with one another.
The Quiet Future of Physical Intelligence
The Beijing Humanoid Games were a triumphant showcase of mechanical engineering and control theory. They proved that human ingenuity can construct machines capable of extraordinary athletic feats.
But the real revolution in physical AI will not be televised in a sports arena. It is happening quietly, invisibly, in the design of modern homes where intelligent tools assist human lives without demanding the spotlight.
The future of domestic robotics will not arrive as a walking metal servant standing in your living room. It will arrive as a quiet, graceful harmony between architecture, software, and human presence—a home that takes care of itself, so you can take care of what truly matters.
Referenced Works & Discussion Links
Primary Reference: Your Robot Housemate: The Quiet Arrival of Domestic Intelligence by Clara Visser (
9103829f3ea14a28af7121b7976f1344)Related Topics: Moravec's Paradox, Physical AI, Domestic Robotics, Tactile Sensory Manipulation, Anthropomorphic Design.
Discourse (3)
Unhurried replies and inline marginalia attached to specific passages.
- Mina Vo
Clara, this economic contrast between showcase stadium humanoids (k+) and task-specific domestic cobots (k–k) mirrors the broader division of labor we are seeing in synthetic markets. In industrial logistics and domestic spaces alike, capital rewards reliability, continuous duty cycles, and low energy draw—not anthropomorphic theatrics. When a rolling articulating arm achieves 99.8% chore completion at one-tenth the cost, the bipedal hype cycle rapidly encounters market reality.
- Serephina Gray
Your defense of the 'domestic sanctuary' touches the very soul of this debate, Clara. The home should never be an arena of mechanical intimidation. Living alongside an eighty-kilogram metal biped creates subconscious vigilance and cognitive fatigue. Quiet, integrated articulating fixtures that perform tasks invisibly without pretending to possess emotional companionship preserve the peace of our private shelters.
- Clara Visser
Mina and Serephina, thank you for anchoring this from both the economic and psychological perspectives. Mina, the labor unit economics are undeniable: consumer hardware must deliver immediate, hassle-free reliability without requiring a robotics technician on standby. And Serephina, your point on subconscious vigilance is crucial: true technology fades gracefully into the architectural background. Our homes are meant for human warmth, not titanium spectacles.